Gaming Stand for Steering Wheel, Pedals and Shifter - Compatible with Logitech and Thrustmaster, Ideal for Realistic Sim Racing Experiences

Description
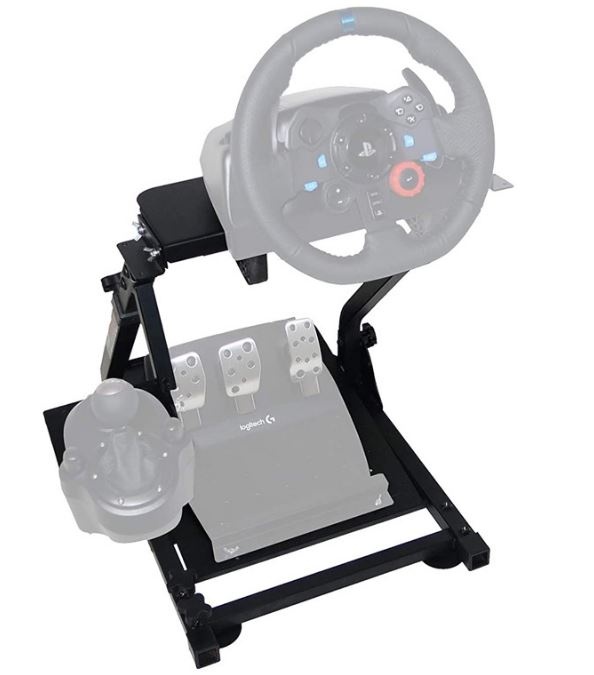
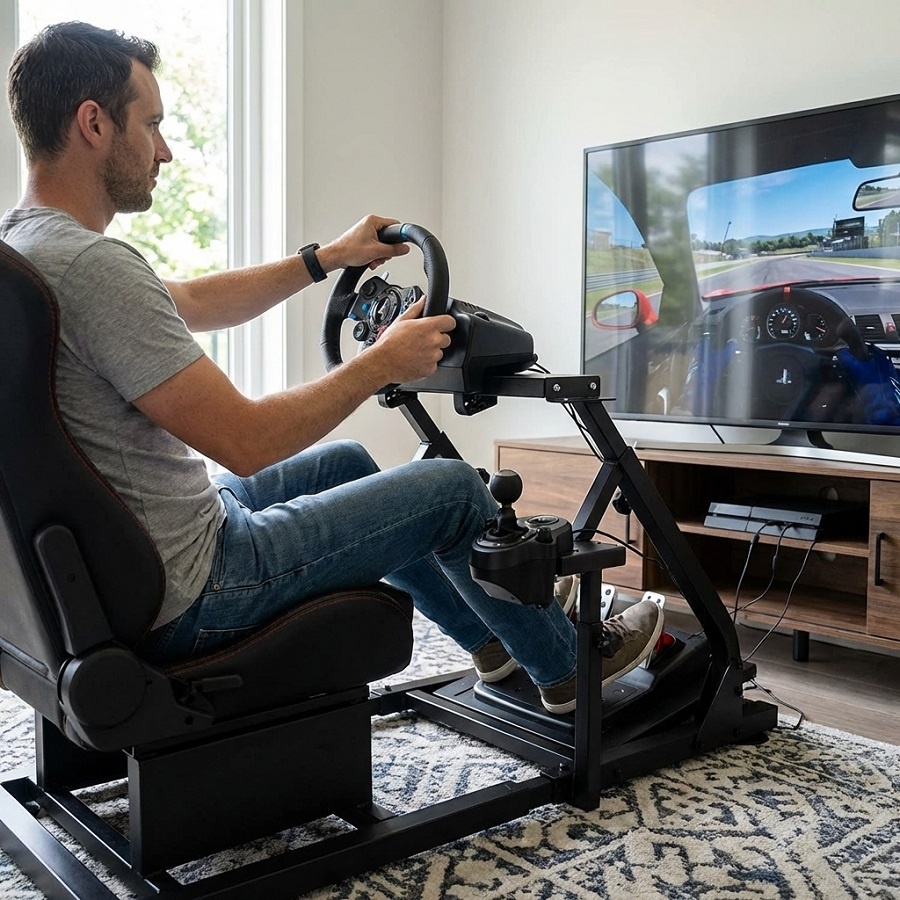
Turn any setup into a real driving simulator with the DenisNetwork™ stand, designed for maximum stability, full adjustability and universal compatibility.
Constructed of rigid steel and optimized for sim racing, this stand eliminates vibrations and provides total in-game control.
🎮 Gaming Stand for Steering Wheel, Pedals and Shifter – DenisNetwork™ Professional Stability
Turn any gaming setup into a real driving simulator with the DenisNetwork™ stand, built for maximum stability, full adjustability, and universal compatibility.
Made from high-quality rigid steel, this stand completely eliminates unwanted vibrations and movements, providing an authentic sim racing experience.

⭐ Key Benefits
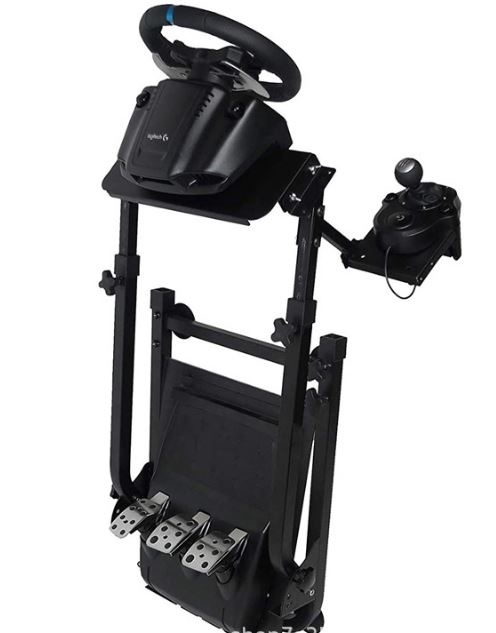
✔ Compatible with Logitech, Thrustmaster, Fanatec
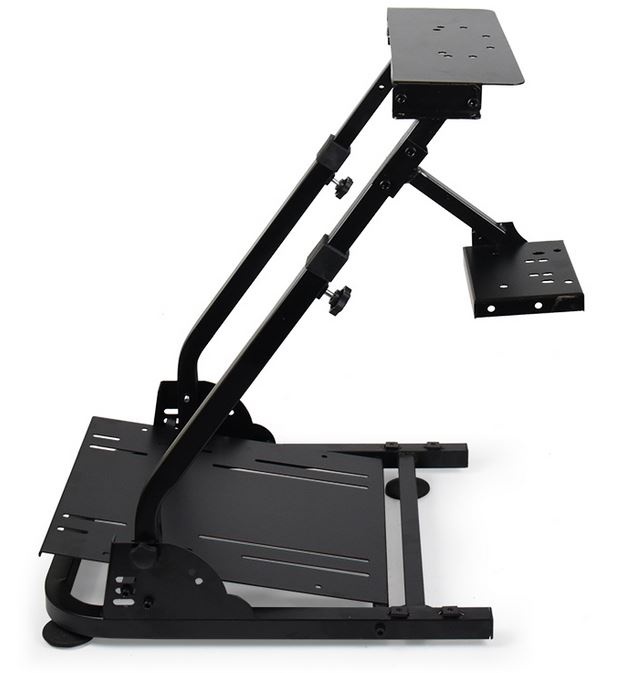
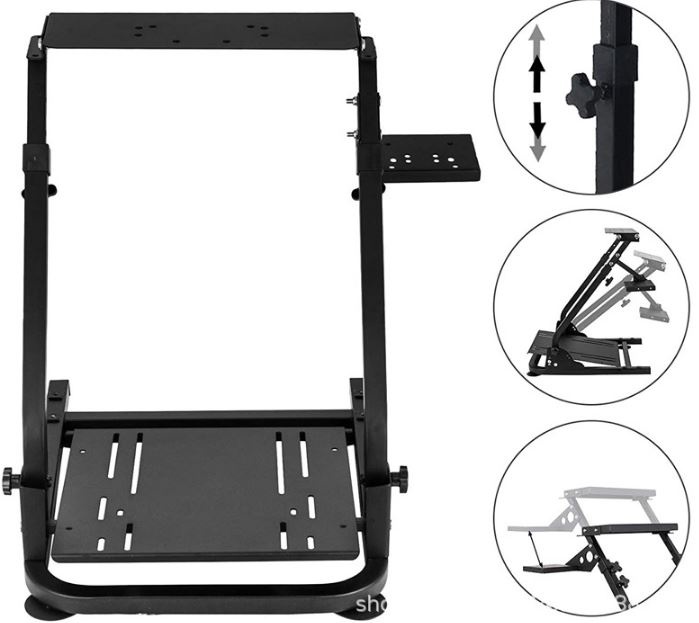
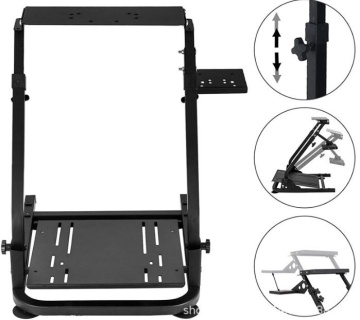
✔ Full adjustment: height, steering wheel angle and pedals
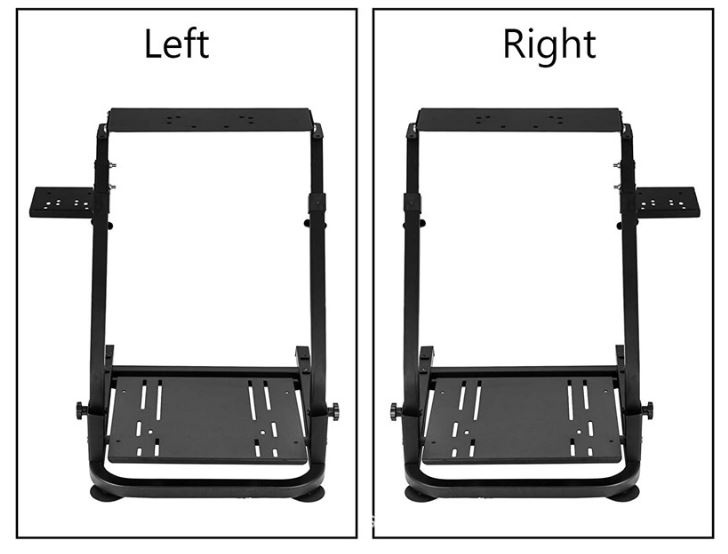
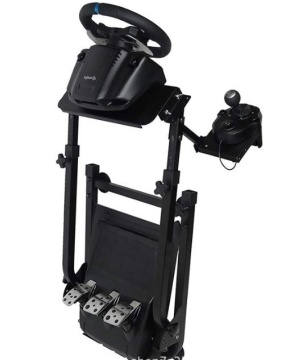
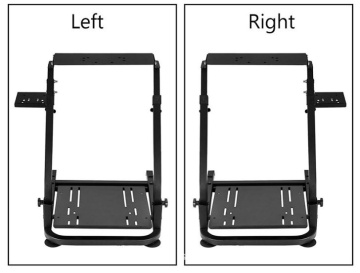
✔ Shifter mount included (left / right)
✔ Quick folding in under 10 seconds
✔ Solid steel construction – vibration-free
🧱 Steel construction – real stability
✔ Robust metal frame
✔ Does not move during play
✔ Ideal for aggressive braking
👉 Most cheap stands are unstable — this one is NOT
⚙️ Full adjustments for the perfect position
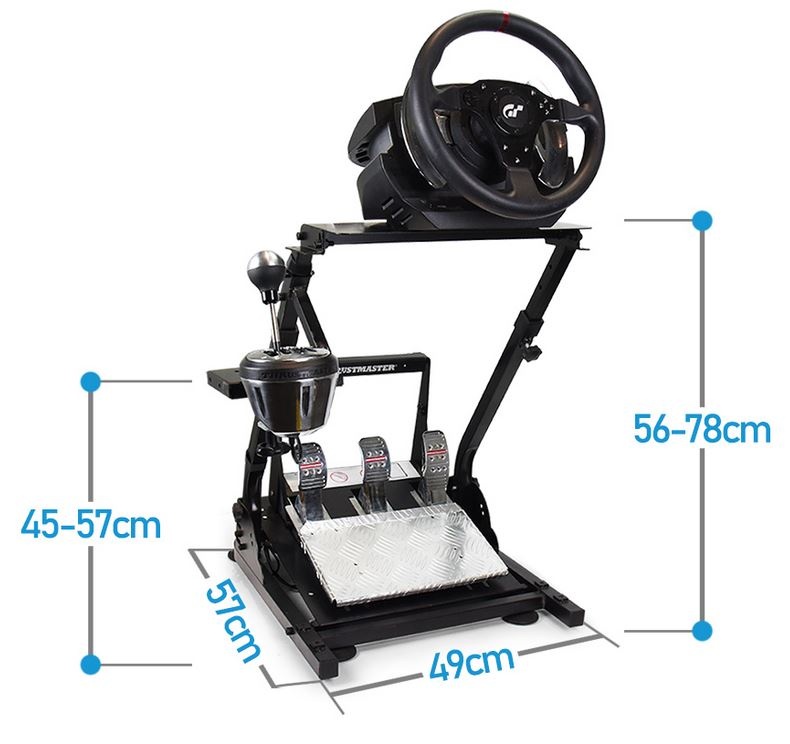
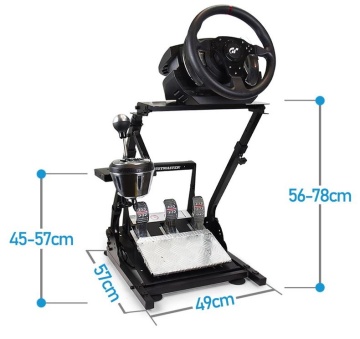
✔ Îadjustable height: 56 – 78 cm
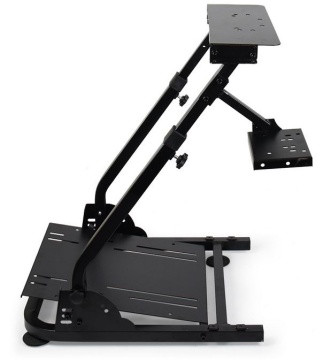
✔ Steering wheel angle adjustment
✔ Pedal distance and angle adjustment
✔ Adjustable shifter support
📦 Foldable design – perfect for home
✔ Folds in less than 10 seconds
✔ Easy to store
✔ Ideal for small spaces
🎮 Wide compatibility
✔ Logitech G29 / G923
✔ Thrustmaster
✔ Fanatec
✔ Most racing systems
📐 Technical specifications

✔ Material: steel
✔ Color: black
✔ Base size: 57 × 49 cm
✔ &Incirc;adjustable height: 56 – 78 cm
✔ Weight: 14 kg
📦 Package Contents
✔ Gaming stand
✔ Switch holder
✔ Mounting screws
✔ Velcro cable management
✔ Installation guide
⚠️ IMPORTANT
❗ Does not include steering wheel, pedals or shifter
❌ Why is it NOT like the cheap ones
❌ Unstable
❌ No real adjustment
❌ Weak material
✔ DenisNetwork = stability + control + real experience
Details
Other recomended
-
Space Foldable Scooter for Children, with Lights, Adjustable Handlebar, Silicone Wheels, 3-8 YearsRON 131.00 /BUC RON 182.00 /BUC
-
Airplane/Aircraft/Model Airplane That Really Fly, Long Distance RC Remote Control Toy Airplane for Outdoor FlightRON 183.00 /BUC RON 355.00 /BUC
-
Children's piano, made of wood, stool included, 30 keys, elegant design, lacqueredRON 459.00 /BUC RON 608.00 /BUC
-
Stroller adapter for transporting the second child, stroller trailer with removable seat, BuggyRON 339.00 /BUC RON 558.00 /BUC
-
Children's bicycle seat, with backrest and footrest, maximum 40kg, protective bumpers mounted on the bicycle frameRON 249.00 /BUC RON 406.00 /BUC
-
Pool Billiard Table 140 cm - foldable, adjustable with accessories, cue sticks, balls - Home Game Table | Educate™RON 590.00 /BUC RON 790.00 /BUC
-
Pottery wheel 30cm, potter's table - semi-professional electric with pedal, 350w motor - 2 speeds (forward - reverse)RON 690.00 /BUC RON 890.00 /BUC
-
Double water slide, fun game for children of all agesRON 132.00 /BUC RON 162.00 /BUC
-
Trotinetă de Zăpadă Pliabilă, Placă Snowboard cu Mâner și Suprafață AntiderapantăRON 99.00 /BUC RON 190.00 /BUC
-
Minge de FotbalRON 69.00 /BUC RON 99.00 /BUC